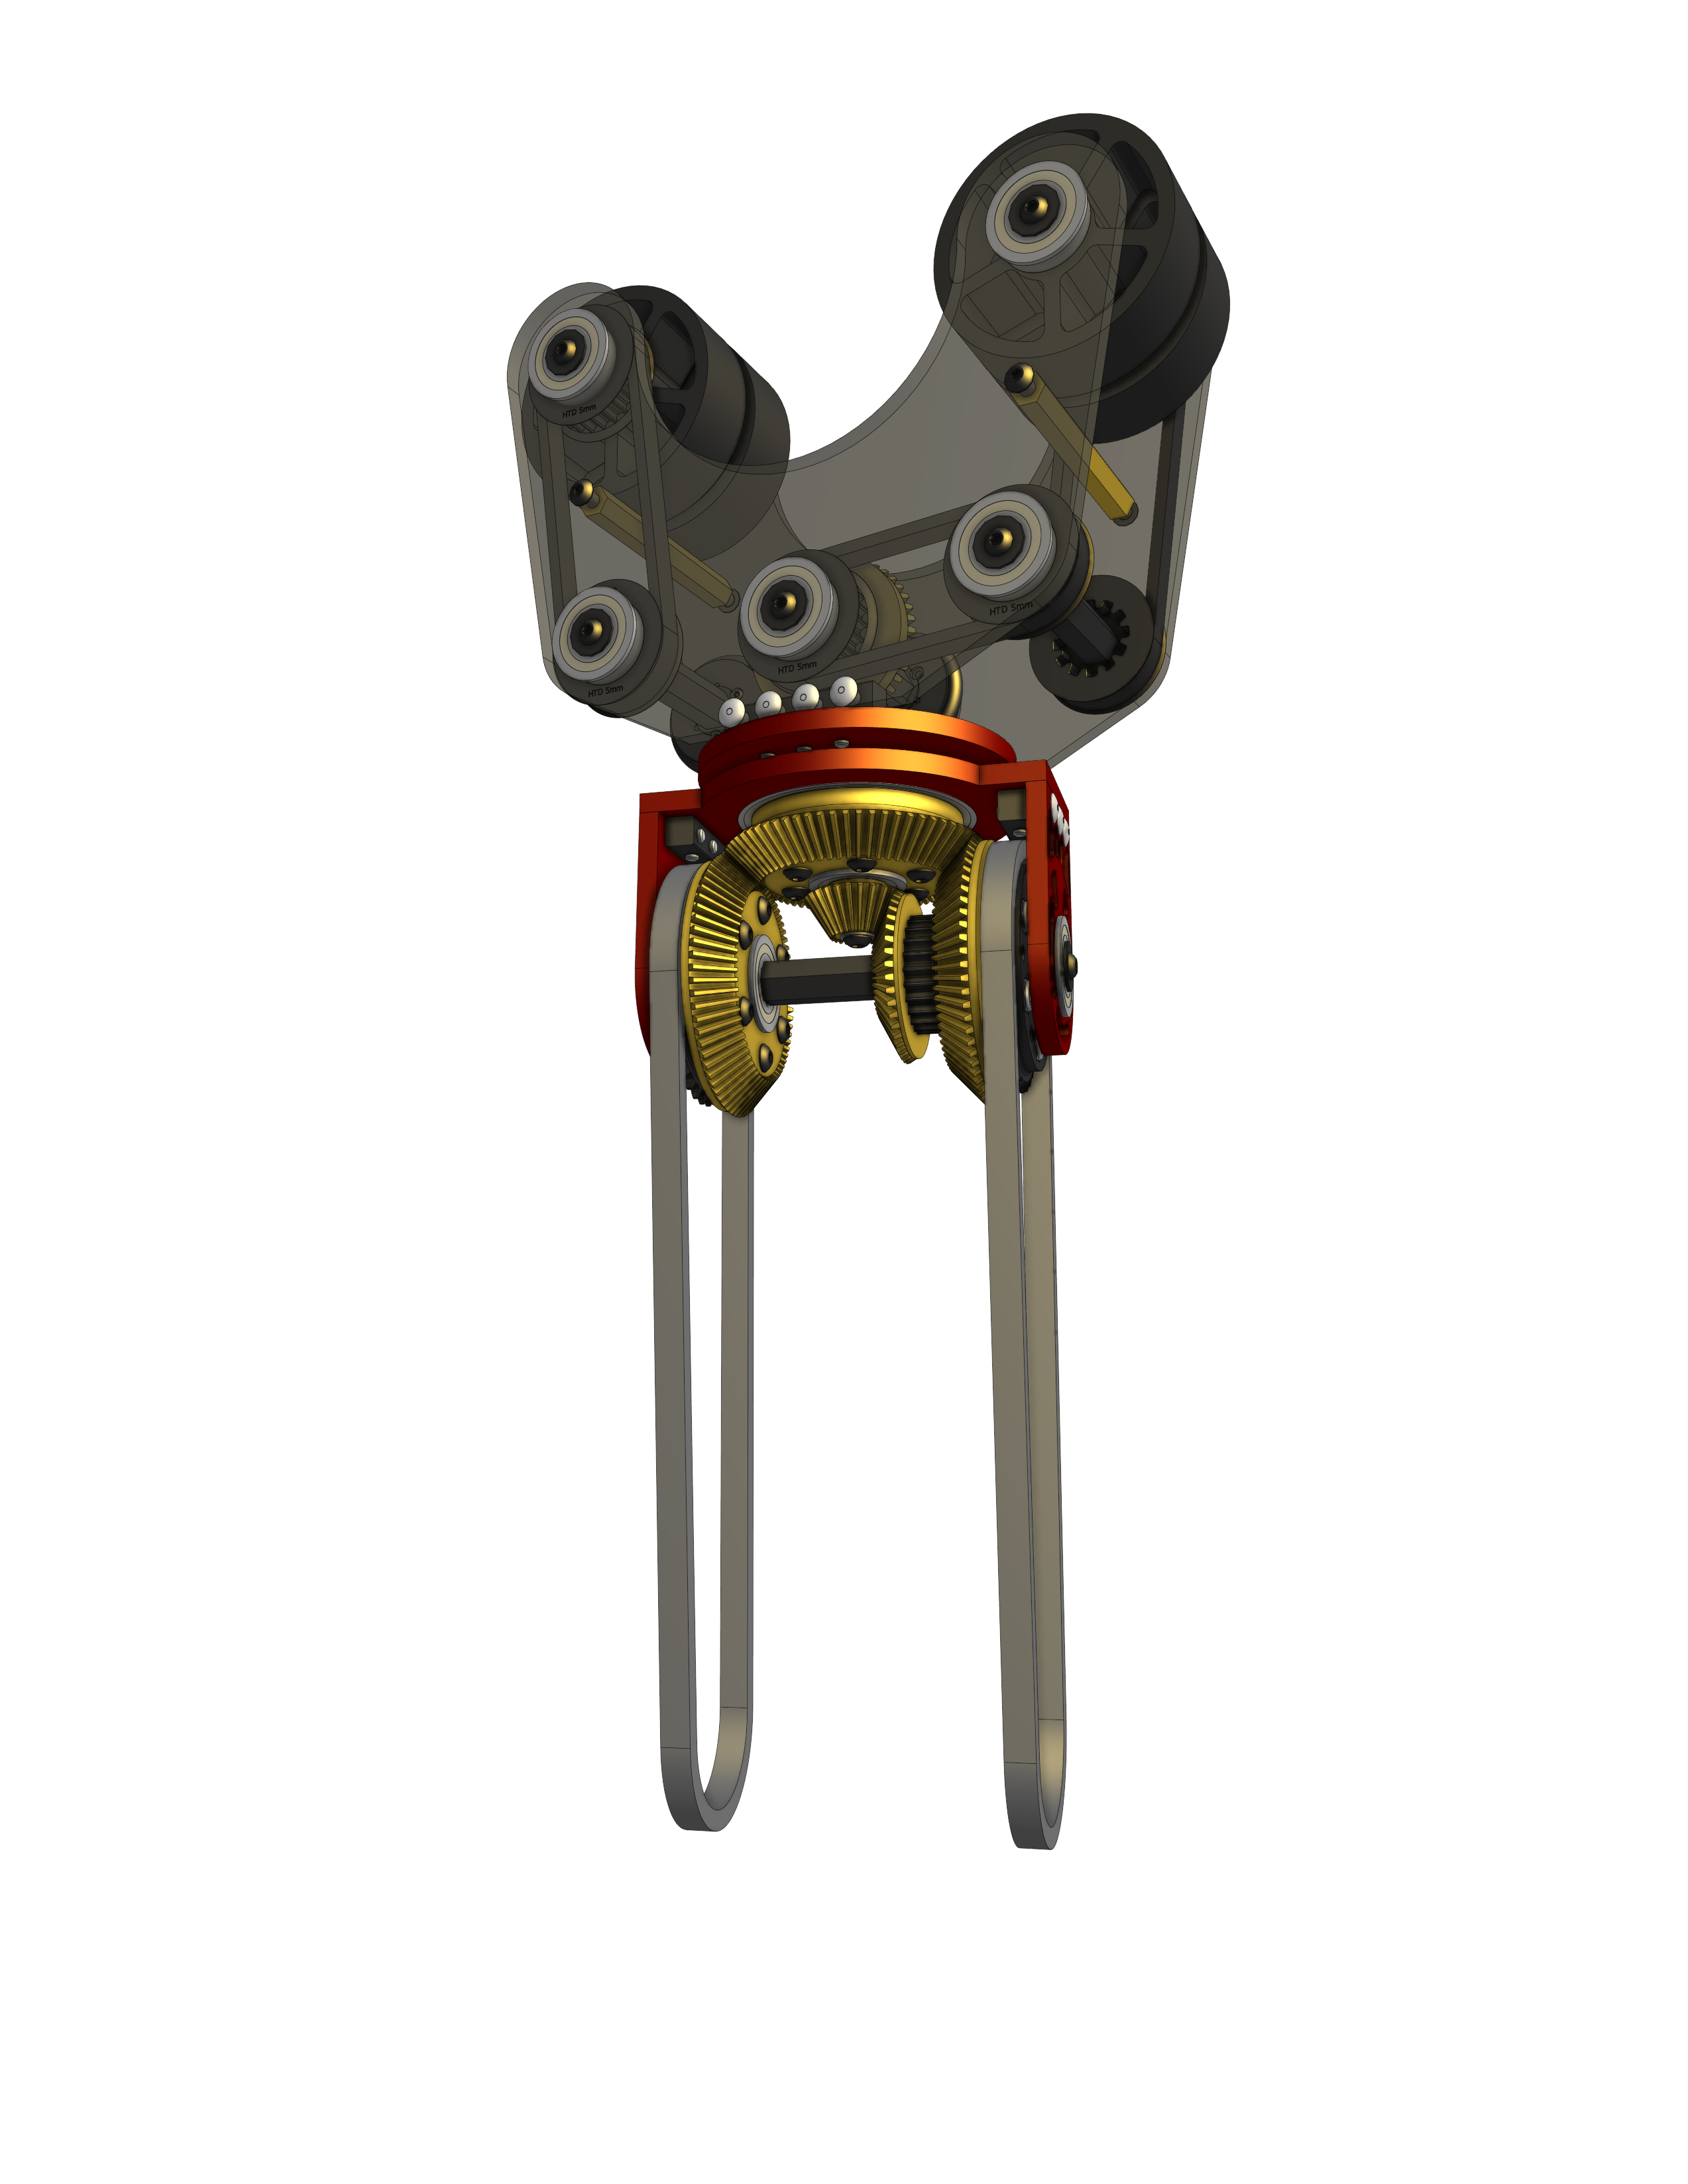
Differential wrist
A differential wrist, CADed after inspiration from 1323's 2025 end effector. Two belt-driven inputs combine through a bevel gear stage to give two independent degrees of freedom from motors mounted back up the arm rather than out at the wrist itself, which keeps the moving mass at the end of the arm low.
Gallery
Credit & Copyright: Processing - Robert Gendler, Roberto Colombari; Data - Hubble Tarantula Treasury, European Southern Observatory